Loading...
Searching...
No Matches
Emrys::PointCells< Path > Struct Template Reference
The cells of a grid of given points (see pointGrid()) for the block named by the path Path: one value per point, under a tag of its own. More...
#include <EmrysFilter/Distributions/GridGaussian.h>
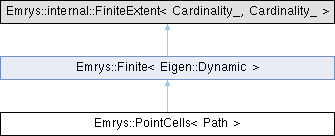
Inheritance diagram for Emrys::PointCells< Path >:
Public Member Functions | |
| Finite ()=default | |
| PointCells are made like a Finite, with their number of points. | |
| constexpr | Finite (Eigen::Index n) |
| PointCells are made like a Finite, with their number of points. | |
Additional Inherited Members | |
| Static Public Attributes inherited from Emrys::Finite< Eigen::Dynamic > | |
| static constexpr int | Cardinality |
| the number of values, or Eigen::Dynamic | |
| static constexpr int | MaxCardinality |
| a bound on it, or Eigen::Dynamic | |
Detailed Description
template<typename Path>
struct Emrys::PointCells< Path >
struct Emrys::PointCells< Path >
The cells of a grid of given points (see pointGrid()) for the block named by the path Path: one value per point, under a tag of its own.
The documentation for this struct was generated from the following file:
- EmrysFilter/Distributions/GridGaussian.h
