Loading...
Searching...
No Matches
Emrys::GridAxis< Block, I > Struct Template Reference
The axis of a regular grid of points (see regularGrid()) along coordinate I of the block Block: a run-time number of cells. More...
#include <EmrysFilter/Distributions/GridGaussian.h>
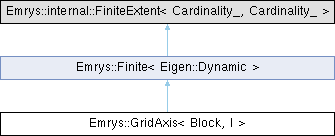
Inheritance diagram for Emrys::GridAxis< Block, I >:
Public Member Functions | |
| Finite ()=default | |
| A GridAxis is made like a Finite, with its number of cells. | |
| constexpr | Finite (Eigen::Index n) |
| A GridAxis is made like a Finite, with its number of cells. | |
Additional Inherited Members | |
| Static Public Attributes inherited from Emrys::Finite< Eigen::Dynamic > | |
| static constexpr int | Cardinality |
| the number of values, or Eigen::Dynamic | |
| static constexpr int | MaxCardinality |
| a bound on it, or Eigen::Dynamic | |
Detailed Description
template<typename Block, int I = 0>
struct Emrys::GridAxis< Block, I >
struct Emrys::GridAxis< Block, I >
The axis of a regular grid of points (see regularGrid()) along coordinate I of the block Block: a run-time number of cells.
Block is the innermost tagged block that holds the coordinate. A grid over Motion : Composite<Heading, Speed> has the axes GridAxis<Heading> and GridAxis<Speed>, and one over Position : Linear<2> the axes GridAxis<Position, 0> and GridAxis<Position, 1>, so the probability of the heading is marginal<GridAxis<Heading>>().
The documentation for this struct was generated from the following file:
- EmrysFilter/Distributions/GridGaussian.h
